01 / Sense
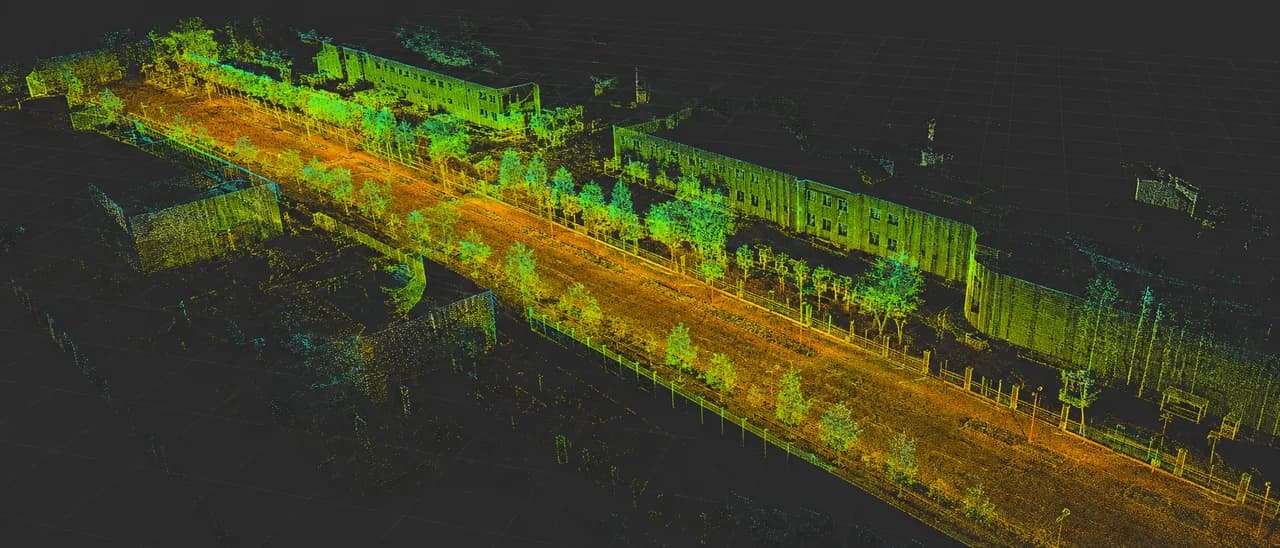
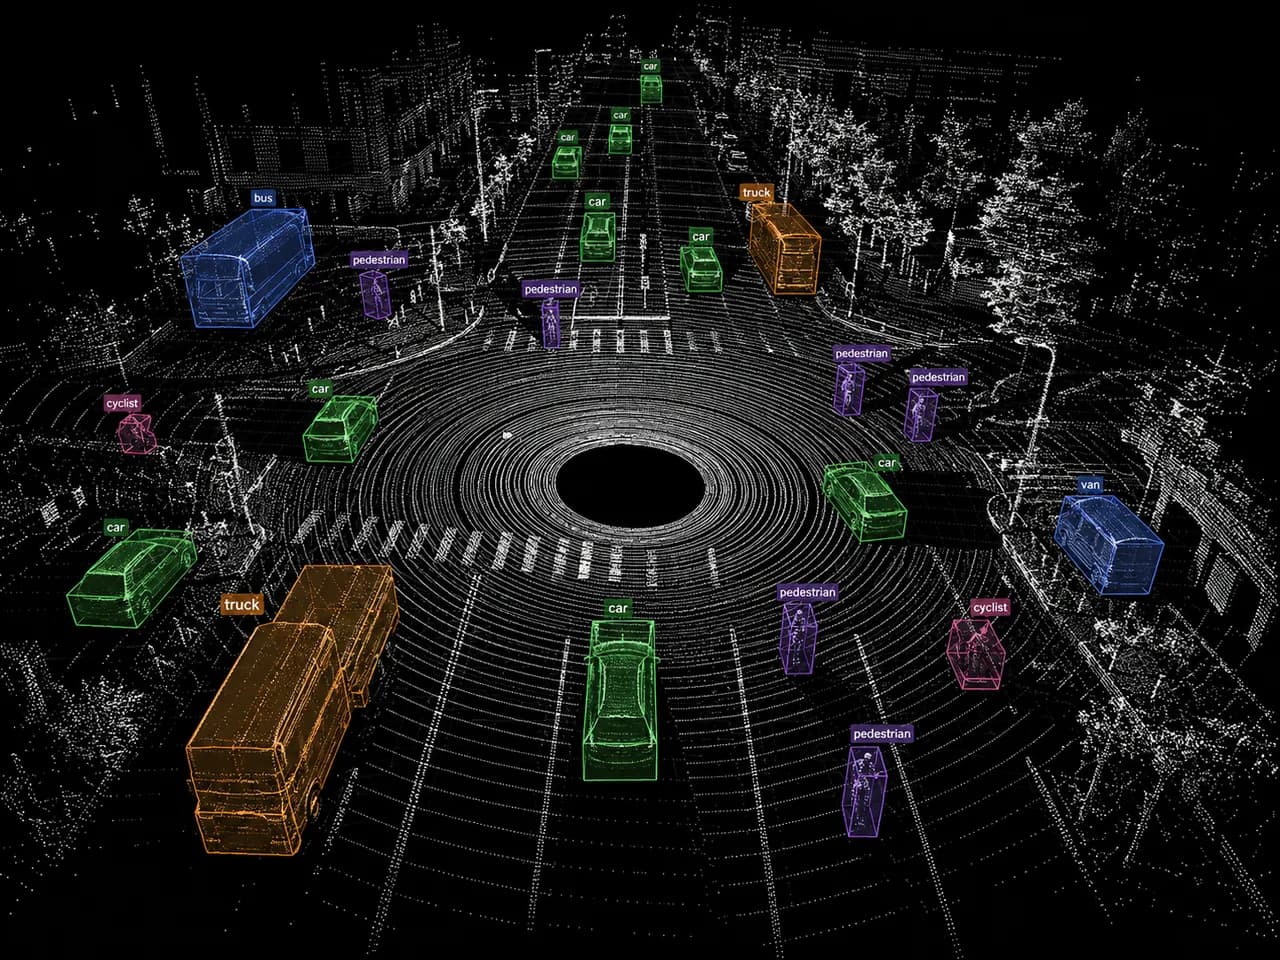
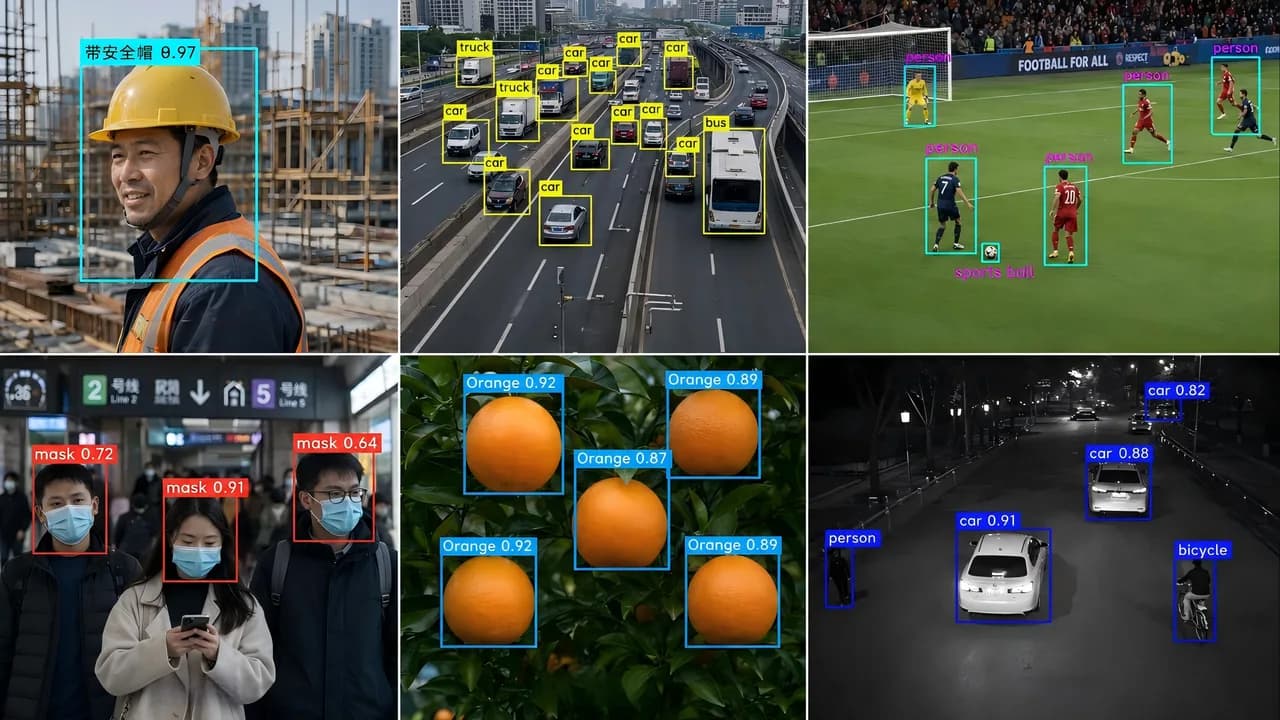
Perception
Capture environmental, device, and target states as reliable inputs for system decisions.
Engineering outputEnvironment models, recognition, state inputs
- Computer vision
- LiDAR
- IMU
- Sensor fusion
ENGINEERING
Starting with robot customization, we connect algorithms, software, embedded hardware and field control to complete real tasks.
Capture environmental, device, and target states as reliable inputs for system decisions.
Engineering outputEnvironment models, recognition, state inputs
Combine rules, algorithms, and models to understand tasks and form action strategies.
Engineering outputDecisions, path planning, task orchestration
Create dependable data paths between devices, edge nodes, and business systems.
Engineering outputData links, protocol adaptation, coordination
Translate algorithm output into stable, real-time, and verifiable device actions.
Engineering outputMotion control, real-time response, edge processing
Manage devices, tasks, data, and operations through one maintainable platform.
Engineering outputSoftware, data platforms, digital mapping
ENGINEERING IN PRACTICE
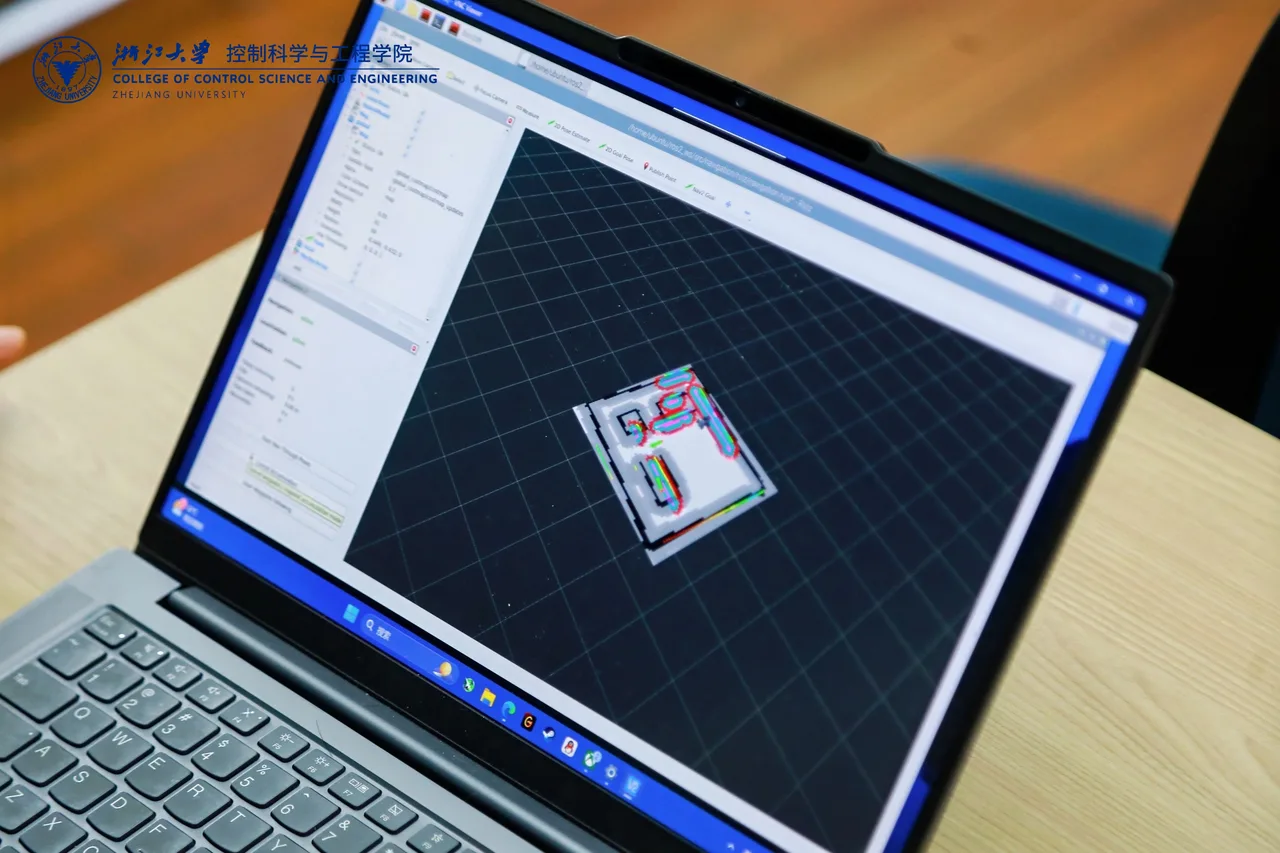
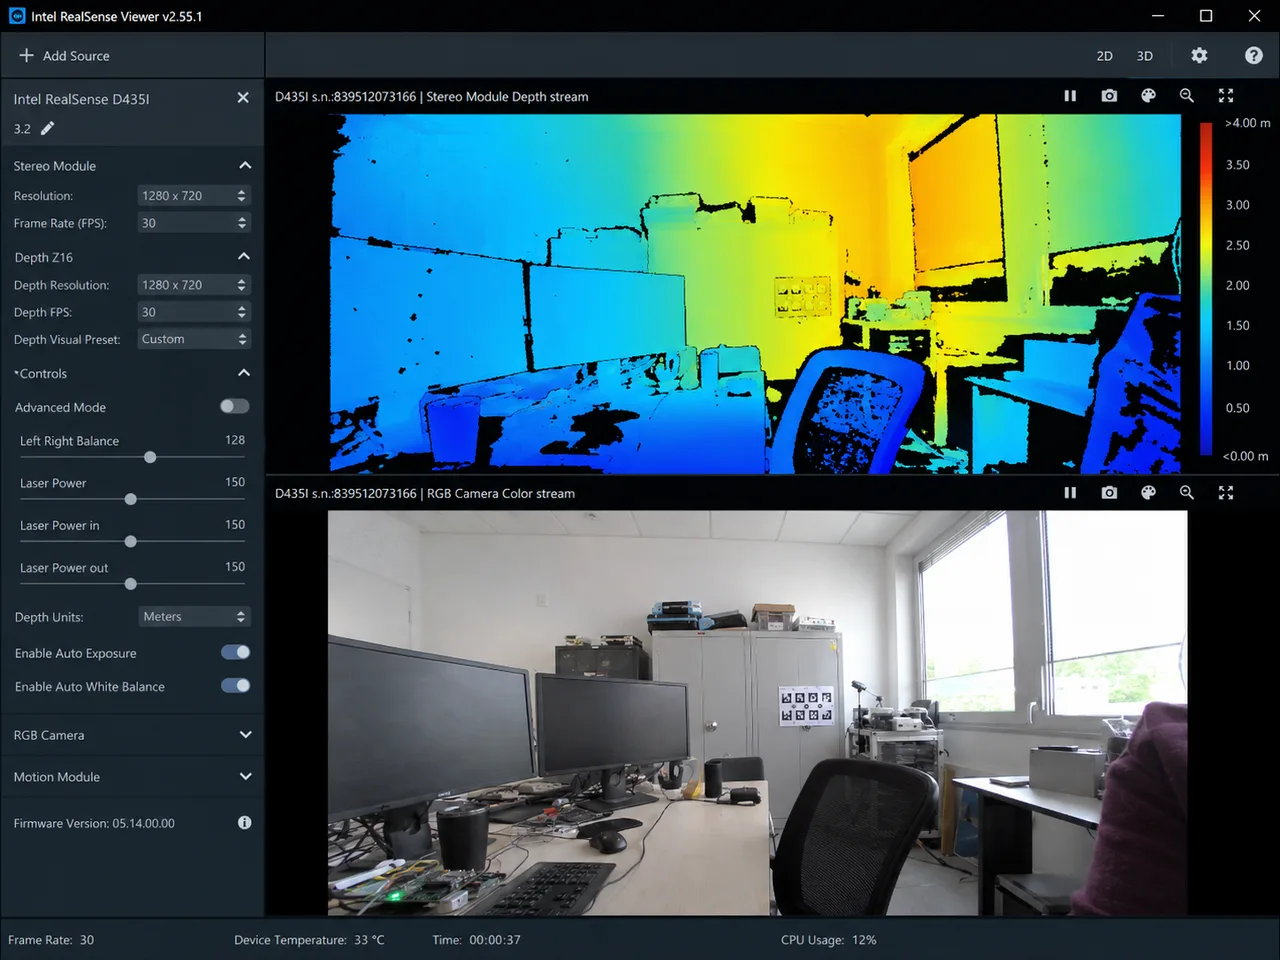
Mapping, perception, control and testing connect algorithms to physical devices.
LET'S BUILD SOMETHING USEFUL
Tell us about your equipment, workflow or learning goals. We will help define the next step.